www.foodpackautomation.com
05
'26
Written on Modified on
Soft Gripping Solutions for Food and Logistics Automation
Schmalz introduces the mGrip Basic finger gripper and the SRCU Basic control module to standardize the delicate handling of irregular products at an optimized cost.
www.schmalz.com
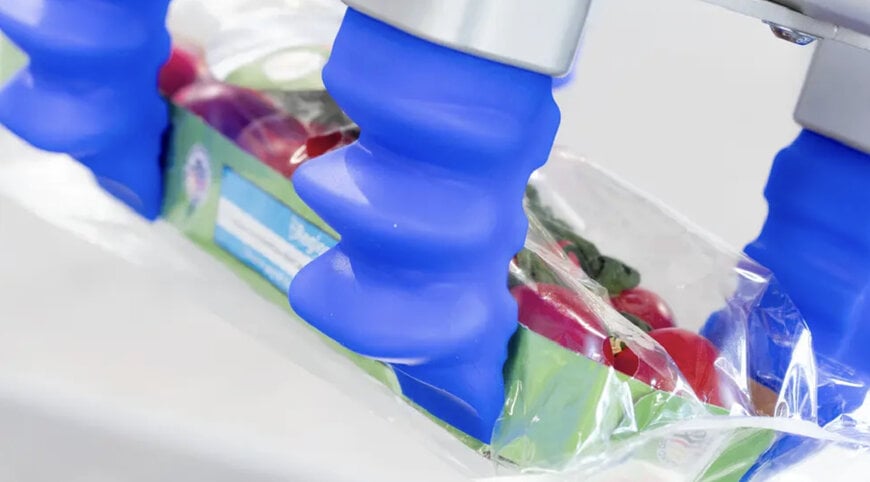
The automated handling of fragile and heterogeneous objects—such as baked goods, fruits, or items packaged in netting—poses a major challenge to conventional mechanical gripping systems. To overcome these geometric and structural limitations, the development of pneumatic soft gripping solutions offers a coordinated approach. These new modules allow delicate handling processes to be integrated into the digital supply chain, thereby reducing economic barriers for the packaging, logistics, and agricultural sectors.
Modular Architecture and Adaptability of the mGrip Basic Gripper
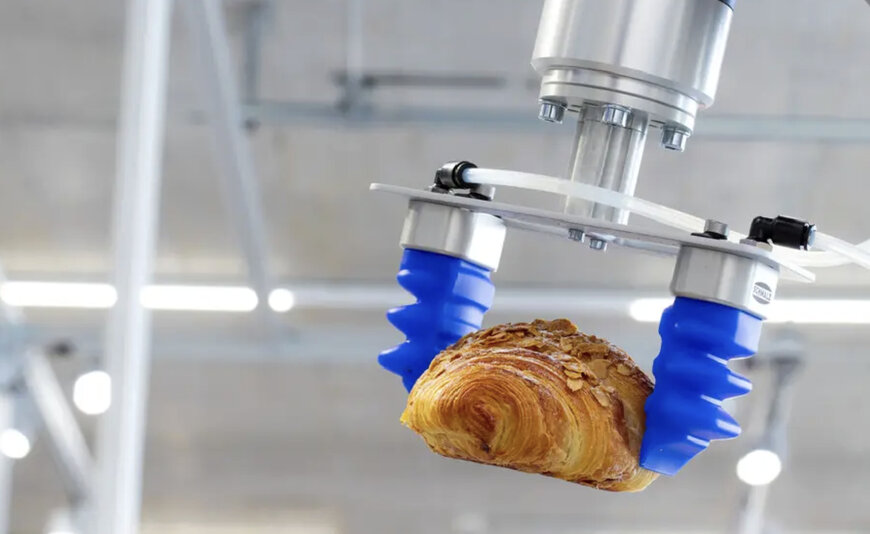
The mGrip Basic pneumatic finger gripper is based on soft finger modules with an adaptive geometry. Unlike rigid kinematics, these elastomer structures conform to the shape of the items without exerting destructive forces, making them ideal for food products or film-wrapped items. The system's flexibility is enhanced by the ability to adjust finger spacing and orientation. Thanks to integrated fastening elements, the modules can be quickly disassembled and reconfigured, transferring product variability to the end-of-arm tooling (EOAT) and minimizing changeover times and investment costs.
Pneumatic Force Control and mGripedia Knowledge Base
To regulate the impact force, the SRCU Basic control module allows manual adjustment of the outlet pressure via a dedicated adjustment knob, with the operator viewing the real-time value on a vacuum switch. A built-in pressure reducer automatically limits the outlet pressure, thereby preventing pneumatic overloading of the soft fingers and extending the operational durability of the system. Designed for cycle rates of up to 120 picks per minute, this module offers a reliable control solution for low-variability production flows.
This hardware infrastructure is coupled with the mGripedia digital platform, a database of over 100 filterable use cases that optimizes the transfer of know-how for integrating complex processes, ensuring flow consistency within the automotive data ecosystem and global logistics networks.
Additional Context: This section details technical specifications and competitive benchmarking not included in the original product announcement
In the soft gripping market, Schmalz's solutions compete with specialized players such as Soft Robotics Inc. (with their original mGrip gripping systems) or adaptive collaborative grippers from OnRobot and Robotiq. While high-end systems often integrate complex digital proportional solenoid valves to regulate pressure, the combination of the mGrip Basic and the SRCU Basic module relies on a purely mechanical and manual approach to regulation. This engineering choice drastically reduces the initial acquisition cost and simplifies maintenance, opening up automation to lower-margin industries such as agricultural sorting or intermediate logistics.
The cycle rate of 120 cycles per minute constitutes a key performance indicator for medium-speed pick-and-place applications. Although rigid mechanical grippers or highly dynamic vacuum suction cups can exceed these speeds, they frequently fail when handling porous surfaces or highly irregular geometries (such as potato nets or croissants). The open architecture of the mGrip Basic, which allows designers to integrate finger modules directly onto custom mounting plates, offers a flexible alternative to closed proprietary solutions, facilitating the interoperability of end-of-arm tooling within modern packaging lines.
Edited by Maria Brueva, Induportals editor – adapted by AI.
www.schmalz.com
